Published by Dimitris Kougioumtzis · Updated
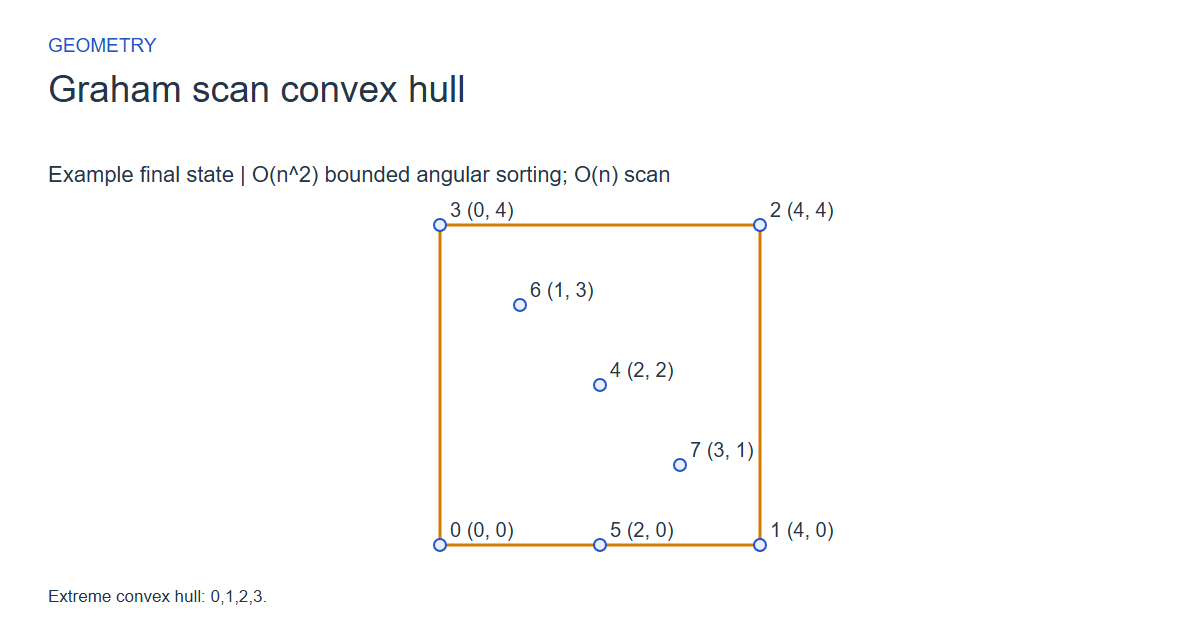
Build the extreme convex boundary while omitting interior collinear points. Actual coordinates use the same scale on both axes.
Sort rays around the lowest pivot, then remove non-left turns with a stack.
When to use Graham scan convex hull
Finding the extreme convex boundary of a planar point set for shape analysis and geometric preprocessing.
Choosing an alternative
Angular sorting exposes the scan invariant; monotone chain instead sorts by coordinates.
Worked example: input and state changes
Example input
0,0;4,0;4,4;0,4;2,2;2,0;1,3;3,1These checkpoints follow the actual example timeline. State details show the stored values and decisions; use the visualization to inspect every intervening step.
Step 0: Coincident points use the first input index. Coordinate axes have equal scale.
State at this checkpoint
{
  "values": [
    0,
    1,
    2,
    3,
    4,
    5,
    6,
    7
  ],
  "active": [],
  "kind": "graph",
  "points": [
    [
      0,
      0
    ],
    [
      4,
      0
    ],
    [
      4,
      4
    ],
    [
      0,
      4
    ],
    [
      2,
      2
    ],
    [
      2,
      0
    ],
    [
      1,
      3
    ],
    [
      3,
      1
    ]
  ],
  "nodeLabels": [
    "0 (0, 0)",
    "1 (4, 0)",
    "2 (4, 4)",
    "3 (0, 4)",
    "4 (2, 2)",
    "5 (2, 0)",
    "6 (1, 3)",
    "7 (3, 1)"
  ],
  "directed": false,
  "chosen": [],
  "visited": [],
  "result": 0,
  "output": []
}
Step 4: Pop a non-left turn; cross product 0.
State at this checkpoint
{
  "values": [
    0,
    1,
    2,
    3,
    4,
    5,
    6,
    7
  ],
  "active": [
    1
  ],
  "kind": "graph",
  "points": [
    [
      0,
      0
    ],
    [
      4,
      0
    ],
    [
      4,
      4
    ],
    [
      0,
      4
    ],
    [
      2,
      2
    ],
    [
      2,
      0
    ],
    [
      1,
      3
    ],
    [
      3,
      1
    ]
  ],
  "nodeLabels": [
    "0 (0, 0)",
    "1 (4, 0)",
    "2 (4, 4)",
    "3 (0, 4)",
    "4 (2, 2)",
    "5 (2, 0)",
    "6 (1, 3)",
    "7 (3, 1)"
  ],
  "directed": false,
  "chosen": [],
  "visited": [
    0
  ],
  "result": 0,
  "output": [
    0
  ]
}
Step 7: Pop a non-left turn; cross product 0.
State at this checkpoint
{
  "values": [
    0,
    1,
    2,
    3,
    4,
    5,
    6,
    7
  ],
  "active": [
    4
  ],
  "kind": "graph",
  "points": [
    [
      0,
      0
    ],
    [
      4,
      0
    ],
    [
      4,
      4
    ],
    [
      0,
      4
    ],
    [
      2,
      2
    ],
    [
      2,
      0
    ],
    [
      1,
      3
    ],
    [
      3,
      1
    ]
  ],
  "nodeLabels": [
    "0 (0, 0)",
    "1 (4, 0)",
    "2 (4, 4)",
    "3 (0, 4)",
    "4 (2, 2)",
    "5 (2, 0)",
    "6 (1, 3)",
    "7 (3, 1)"
  ],
  "directed": false,
  "chosen": [
    0
  ],
  "visited": [
    0,
    1
  ],
  "result": 0,
  "output": [
    0,
    1
  ]
}
Step 11: Push the next angular point.
State at this checkpoint
{
  "values": [
    0,
    1,
    2,
    3,
    4,
    5,
    6,
    7
  ],
  "active": [
    6
  ],
  "kind": "graph",
  "points": [
    [
      0,
      0
    ],
    [
      4,
      0
    ],
    [
      4,
      4
    ],
    [
      0,
      4
    ],
    [
      2,
      2
    ],
    [
      2,
      0
    ],
    [
      1,
      3
    ],
    [
      3,
      1
    ]
  ],
  "nodeLabels": [
    "0 (0, 0)",
    "1 (4, 0)",
    "2 (4, 4)",
    "3 (0, 4)",
    "4 (2, 2)",
    "5 (2, 0)",
    "6 (1, 3)",
    "7 (3, 1)"
  ],
  "directed": false,
  "chosen": [
    0,
    1,
    2
  ],
  "visited": [
    0,
    1,
    2,
    6
  ],
  "result": 0,
  "output": [
    0,
    1,
    2,
    6
  ]
}
Step 14: Extreme convex hull: 0,1,2,3.
State at this checkpoint
{
  "values": [
    0,
    1,
    2,
    3,
    4,
    5,
    6,
    7
  ],
  "active": [],
  "kind": "graph",
  "points": [
    [
      0,
      0
    ],
    [
      4,
      0
    ],
    [
      4,
      4
    ],
    [
      0,
      4
    ],
    [
      2,
      2
    ],
    [
      2,
      0
    ],
    [
      1,
      3
    ],
    [
      3,
      1
    ]
  ],
  "nodeLabels": [
    "0 (0, 0)",
    "1 (4, 0)",
    "2 (4, 4)",
    "3 (0, 4)",
    "4 (2, 2)",
    "5 (2, 0)",
    "6 (1, 3)",
    "7 (3, 1)"
  ],
  "directed": false,
  "chosen": [
    0,
    1,
    2,
    3
  ],
  "visited": [
    0,
    1,
    2,
    3
  ],
  "result": 4,
  "output": [
    0,
    1,
    2,
    3
  ]
}
Expected final state
Extreme convex hull: 0,1,2,3.
Complexity and input bounds
Family: Geometry. Time complexity: O(n^2) bounded angular sorting; O(n) scan.
Implementation detail: Coordinates are integers -20..20, with at most twelve input points. Downloads accept separate x and y arrays and return the hull count while writing original point indices counterclockwise from the lexicographic minimum. Empty native input returns zero. Both displays preserve equal coordinate scale. Independent supporting-line fixtures verify extrema, duplicates and degenerate inputs in all nine languages.
Space complexity: O(n) working point and hull storage, plus recorded visualization frames.
Working-space bounds describe algorithm state and any explicitly noted output, excluding the visualization's saved timeline. Recording frames can use more memory than running the function alone. Here n is sequence length, V and E are vertex and edge counts, and other parameters refer to the named input dimensions.
1..12 points x,y separated by ;, integer coordinates -20..20. Coincident points use their first input index; output is CCW from the lexicographic minimum.
The playground validates these limits before starting. Downloaded functions are callable implementations, with parameter and output-buffer contracts in their comments; they do not all repeat the playground's input validation.
Common mistakes and limitations
Retain the first index for coincident points. Exclude interior collinear points, handle a single unique point and all-collinear sets, and canonicalize orientation before comparing hulls.
Further reading
For background on algorithm analysis and the JavaScript function interface:
- MIT OpenCourseWare: algorithm design and analysis foundations
- MDN: JavaScript function parameters and return values
Editorial and testing approach · Browse all algorithm guides
Complete JavaScript implementation
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 | // Planar convex hull, n 0..12 integer x/y coordinates -20..20, output capacity n. Returns number of extreme hull vertices and writes original input indices counterclockwise from lexicographically smallest coordinate. Coincident points use first input index; interior collinear boundary points are omitted. Collinear input returns its two endpoints, one unique point returns one, empty returns zero. Coordinates are unchanged; all orientation/distance tests use exact bounded integer arithmetic. Portable versions use O(n^2) stable index preprocessing (and angular insertion sorting for Graham); monotone/Graham scans are O(n), Jarvis wrapping O(n*h), Quickhull worst case O(n^2). Fixed O(n) scratch/explicit stacks; Python uses its standard index sort and recursive Quickhull. Reference snippets assume validated playground inputs. Fixed scratch buffers have 256 slots. Sorting variants may use a different traversal strategy than the animation. function algorithm(x, y, n, output) { if (n == 0) { return 0; } let order = Array(256).fill(0); let points = Array(256).fill(0); let hull = Array(256).fill(0); let key = 0; let cursor = 0; let count = 0; let id = 0; let size = 0; for (let i = 0; i < n; i++) { order[i] = i; } for (let i = 1; i < n; i++) { key = order[i]; cursor = i-1; while (cursor >= 0 && (x[order[cursor]] > x[key] || (x[order[cursor]] == x[key] && y[order[cursor]] > y[key]))) { order[cursor+1] = order[cursor]; cursor--; } order[cursor+1] = key; } for (let i = 0; i < n; i++) { id = order[i]; if (count == 0 || x[id] != x[points[count-1]] || y[id] != y[points[count-1]]) { points[count] = id; count++; } } if (count == 1) { output[0] = points[0]; return 1; } let pivotIndex = 0; let pivot = 0; let turn = 0; let previousDistance = 0; let keyDistance = 0; for (let i = 1; i < count; i++) { if (y[points[i]] < y[points[pivotIndex]] || (y[points[i]] == y[points[pivotIndex]] && x[points[i]] < x[points[pivotIndex]])) { pivotIndex = i; } } pivot = points[pivotIndex]; points[pivotIndex] = points[0]; points[0] = pivot; for (let i = 2; i < count; i++) { key = points[i]; cursor = i-1; while (cursor >= 1) { turn = ((x[points[cursor]]-x[pivot])*(y[key]-y[pivot])-(y[points[cursor]]-y[pivot])*(x[key]-x[pivot])); previousDistance = ((x[pivot]-x[points[cursor]])*(x[pivot]-x[points[cursor]])+(y[pivot]-y[points[cursor]])*(y[pivot]-y[points[cursor]])); keyDistance = ((x[pivot]-x[key])*(x[pivot]-x[key])+(y[pivot]-y[key])*(y[pivot]-y[key])); if (turn < 0 || (turn == 0 && previousDistance > keyDistance)) { points[cursor+1] = points[cursor]; cursor--; } else { break; } } points[cursor+1] = key; } for (let i = 0; i < count; i++) { while (size >= 2 && ((x[hull[size-1]]-x[hull[size-2]])*(y[points[i]]-y[hull[size-2]])-(y[hull[size-1]]-y[hull[size-2]])*(x[points[i]]-x[hull[size-2]])) <= 0) { size--; } hull[size] = points[i]; size++; } let area = 0; let best = 0; let nextIndex = 0; let swapValue = 0; let left = 0; let right = 0; for (let i = 0; i < size; i++) { nextIndex = (i+1)%size; area += x[hull[i]]*y[hull[nextIndex]]-y[hull[i]]*x[hull[nextIndex]]; } if (area < 0) { left = 0; right = size-1; while (left < right) { swapValue = hull[left]; hull[left] = hull[right]; hull[right] = swapValue; left++; right--; } } for (let i = 1; i < size; i++) { if (x[hull[i]] < x[hull[best]] || (x[hull[i]] == x[hull[best]] && y[hull[i]] < y[hull[best]])) { best = i; } } for (let i = 0; i < size; i++) { output[i] = hull[(best+i)%size]; } return size; } |
Source
Primary research for the named hull method. This bounded teaching implementation uses insertion-based preprocessing, so its stated complexity includes quadratic sorting rather than claiming an optimal library sort.
- An efficient algorith for determining the convex hull of a finite planar set
R.L. Graham (1972). Research paper.
