Published by Dimitris Kougioumtzis · Updated
Treat each input edge as undirected. Skip only the parent edge, preserving parallel edges; compare discovery times and low links.
A non-root is a cut vertex when a child subtree cannot bypass it to a strict ancestor; a root requires multiple DFS children.
When to use Articulation points (low-link DFS)
Finding single-vertex undirected network vulnerabilities.
Choosing an alternative
Bridges identify fragile edges rather than vertices.
Worked example: input and state changes
Example input
0,1,1;1,2,1;2,0,1;2,3,1;3,4,1;4,3,1These checkpoints follow the actual example timeline. State details show the stored values and decisions; use the visualization to inspect every intervening step.
Step 0: Initialize graph state.
State at this checkpoint
{
  "values": [
    "-",
    "-",
    "-",
    "-",
    "-"
  ],
  "active": [],
  "kind": "graph",
  "chosen": [],
  "visited": []
}
Step 4: Inspect non-parent edge #2; update low[2]=0.
State at this checkpoint
{
  "values": [
    "d:0 l:0",
    "d:1 l:1",
    "d:2 l:0",
    "d:-1 l:-1",
    "d:-1 l:-1"
  ],
  "active": [
    2,
    0
  ],
  "kind": "graph",
  "chosen": [],
  "visited": [],
  "discovery": [
    0,
    1,
    2,
    -1,
    -1
  ],
  "low": [
    0,
    1,
    0,
    -1,
    -1
  ],
  "bridgeEdges": [],
  "cutVertices": []
}
Step 7: Inspect non-parent edge #5; update low[4]=3.
State at this checkpoint
{
  "values": [
    "d:0 l:0",
    "d:1 l:1",
    "d:2 l:0",
    "d:3 l:3",
    "d:4 l:3"
  ],
  "active": [
    4,
    3
  ],
  "kind": "graph",
  "chosen": [],
  "visited": [],
  "discovery": [
    0,
    1,
    2,
    3,
    4
  ],
  "low": [
    0,
    1,
    0,
    3,
    3
  ],
  "bridgeEdges": [],
  "cutVertices": []
}
Step 11: Return 2 > 1; low[2]=0, discovery[1]=1.
State at this checkpoint
{
  "values": [
    "d:0 l:0",
    "d:1 l:0",
    "d:2 l:0 cut",
    "d:3 l:3 cut",
    "d:4 l:3"
  ],
  "active": [
    1,
    2
  ],
  "kind": "graph",
  "chosen": [
    3
  ],
  "visited": [],
  "discovery": [
    0,
    1,
    2,
    3,
    4
  ],
  "low": [
    0,
    0,
    0,
    3,
    3
  ],
  "bridgeEdges": [
    3
  ],
  "cutVertices": [
    2,
    3
  ]
}
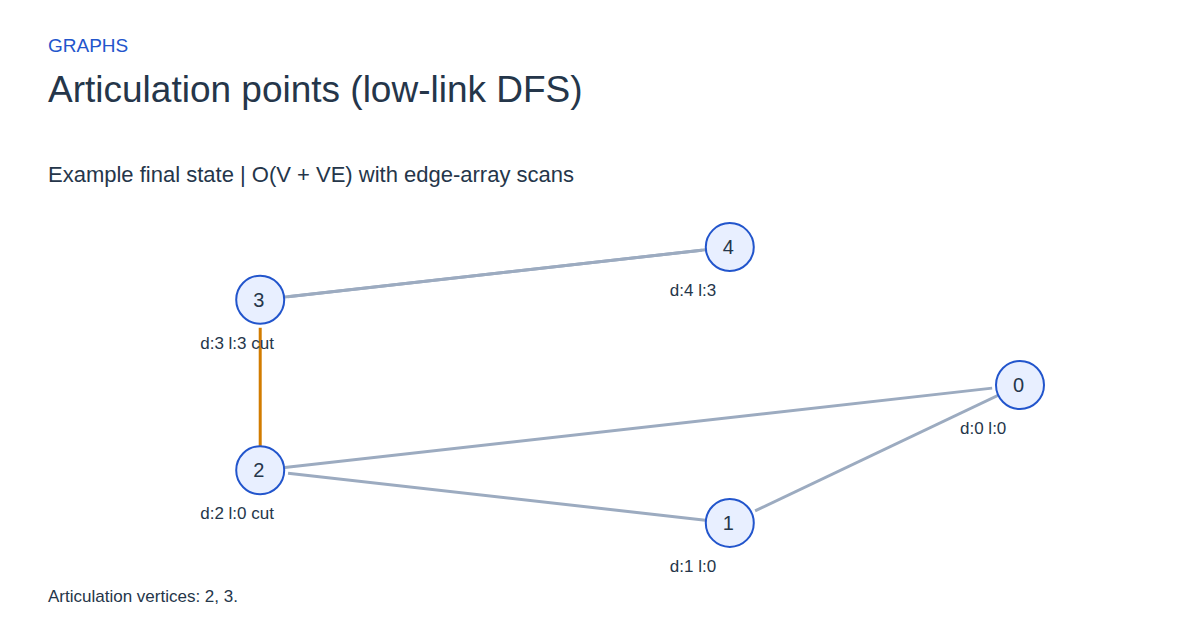
Step 14: Articulation vertices: 2, 3.
State at this checkpoint
{
  "values": [
    "d:0 l:0",
    "d:1 l:0",
    "d:2 l:0 cut",
    "d:3 l:3 cut",
    "d:4 l:3"
  ],
  "active": [],
  "kind": "graph",
  "chosen": [
    3
  ],
  "visited": [
    2,
    3
  ],
  "result": 2,
  "bridgeEdges": [
    3
  ],
  "cutVertices": [
    2,
    3
  ],
  "discovery": [
    0,
    1,
    2,
    3,
    4
  ],
  "low": [
    0,
    0,
    0,
    3,
    3
  ]
}
Expected final state
Articulation vertices: 2, 3.
Complexity and input bounds
Family: Graphs. Time complexity: O(V + VE) with edge-array scans.
Space complexity: O(V) discovery, low-link, and cut flags.
Working-space bounds describe algorithm state and any explicitly noted output, excluding the visualization's saved timeline. Recording frames can use more memory than running the function alone. Here n is sequence length, V and E are vertex and edge counts, and other parameters refer to the named input dimensions.
Directed edges as source,target,weight; separated by semicolons. Nodes 0–7, positive weights 1–99. Start node is 0. At most 16 edges. Weights are ignored. Edges are undirected; duplicate edges are distinct.
The playground validates these limits before starting. Downloaded functions are callable implementations, with parameter and output-buffer contracts in their comments; they do not all repeat the playground's input validation.
Common mistakes and limitations
The root rule differs from the non-root rule and must be applied separately in every component.
Further reading
For background on algorithm analysis and the JavaScript function interface:
- MIT OpenCourseWare: algorithm design and analysis foundations
- MDN: JavaScript function parameters and return values
Editorial and testing approach · Browse all algorithm guides
Complete JavaScript implementation
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 | // Edge arrays from/to/weight; 1..8 vertices indexed 0..vertices-1, 0..16 edges, endpoints in bounds. Weights ignored. Output buffer at least 256 integers. Treat edges as undirected; parallel edges are distinct. Returns count and writes one 0/1 articulation flag per vertex. Reference snippets assume validated playground inputs. Fixed scratch buffers have 256 slots. Sorting variants may use a different traversal strategy than the animation. function algorithm(from, to, weight, edges, vertices, output) { let disc = Array(256).fill(0); let low = Array(256).fill(0); let parent = Array(256).fill(0); let parentEdge = Array(256).fill(0); let cursor = Array(256).fill(0); let children = Array(256).fill(0); let dfs = Array(256).fill(0); let cut = Array(256).fill(0); let bridge = Array(256).fill(0); let root = 0; let u = 0; let v = 0; let index = 0; let top = 0; let clock = 0; let count = 0; for (u = 0; u < vertices; u++) { disc[u] = -1; parent[u] = -1; parentEdge[u] = -1; } for (root = 0; root < vertices; root++) { if (disc[root] >= 0) { continue; } disc[root] = clock; low[root] = clock++; dfs[top++] = root; while (top > 0) { u = dfs[top - 1]; index = cursor[u]; while (index < edges && (index == parentEdge[u] || (from[index] != u && to[index] != u))) { index++; } cursor[u] = index + 1; if (index < edges) { v = from[index]; if (v == u) { v = to[index]; } if (disc[v] < 0) { parent[v] = u; parentEdge[v] = index; children[u]++; disc[v] = clock; low[v] = clock++; dfs[top++] = v; } else if (disc[v] < low[u]) { low[u] = disc[v]; } } else { top--; v = parent[u]; if (v < 0) { if (children[u] > 1) { cut[u] = 1; } } else { if (low[u] < low[v]) { low[v] = low[u]; } if (low[u] > disc[v]) { bridge[parentEdge[u]] = 1; } if (parent[v] >= 0 && low[u] >= disc[v]) { cut[v] = 1; } } } } } for (index = 0; index < vertices; index++) { output[index] = cut[index]; count += output[index]; } return count; } |
Source
Primary research source for the algorithm or its underlying method. The playground is a bounded teaching implementation, not the publication's original program.
- Depth-First Search and Linear Graph Algorithms
Robert Tarjan (1972). Research paper.
